ABOUT US
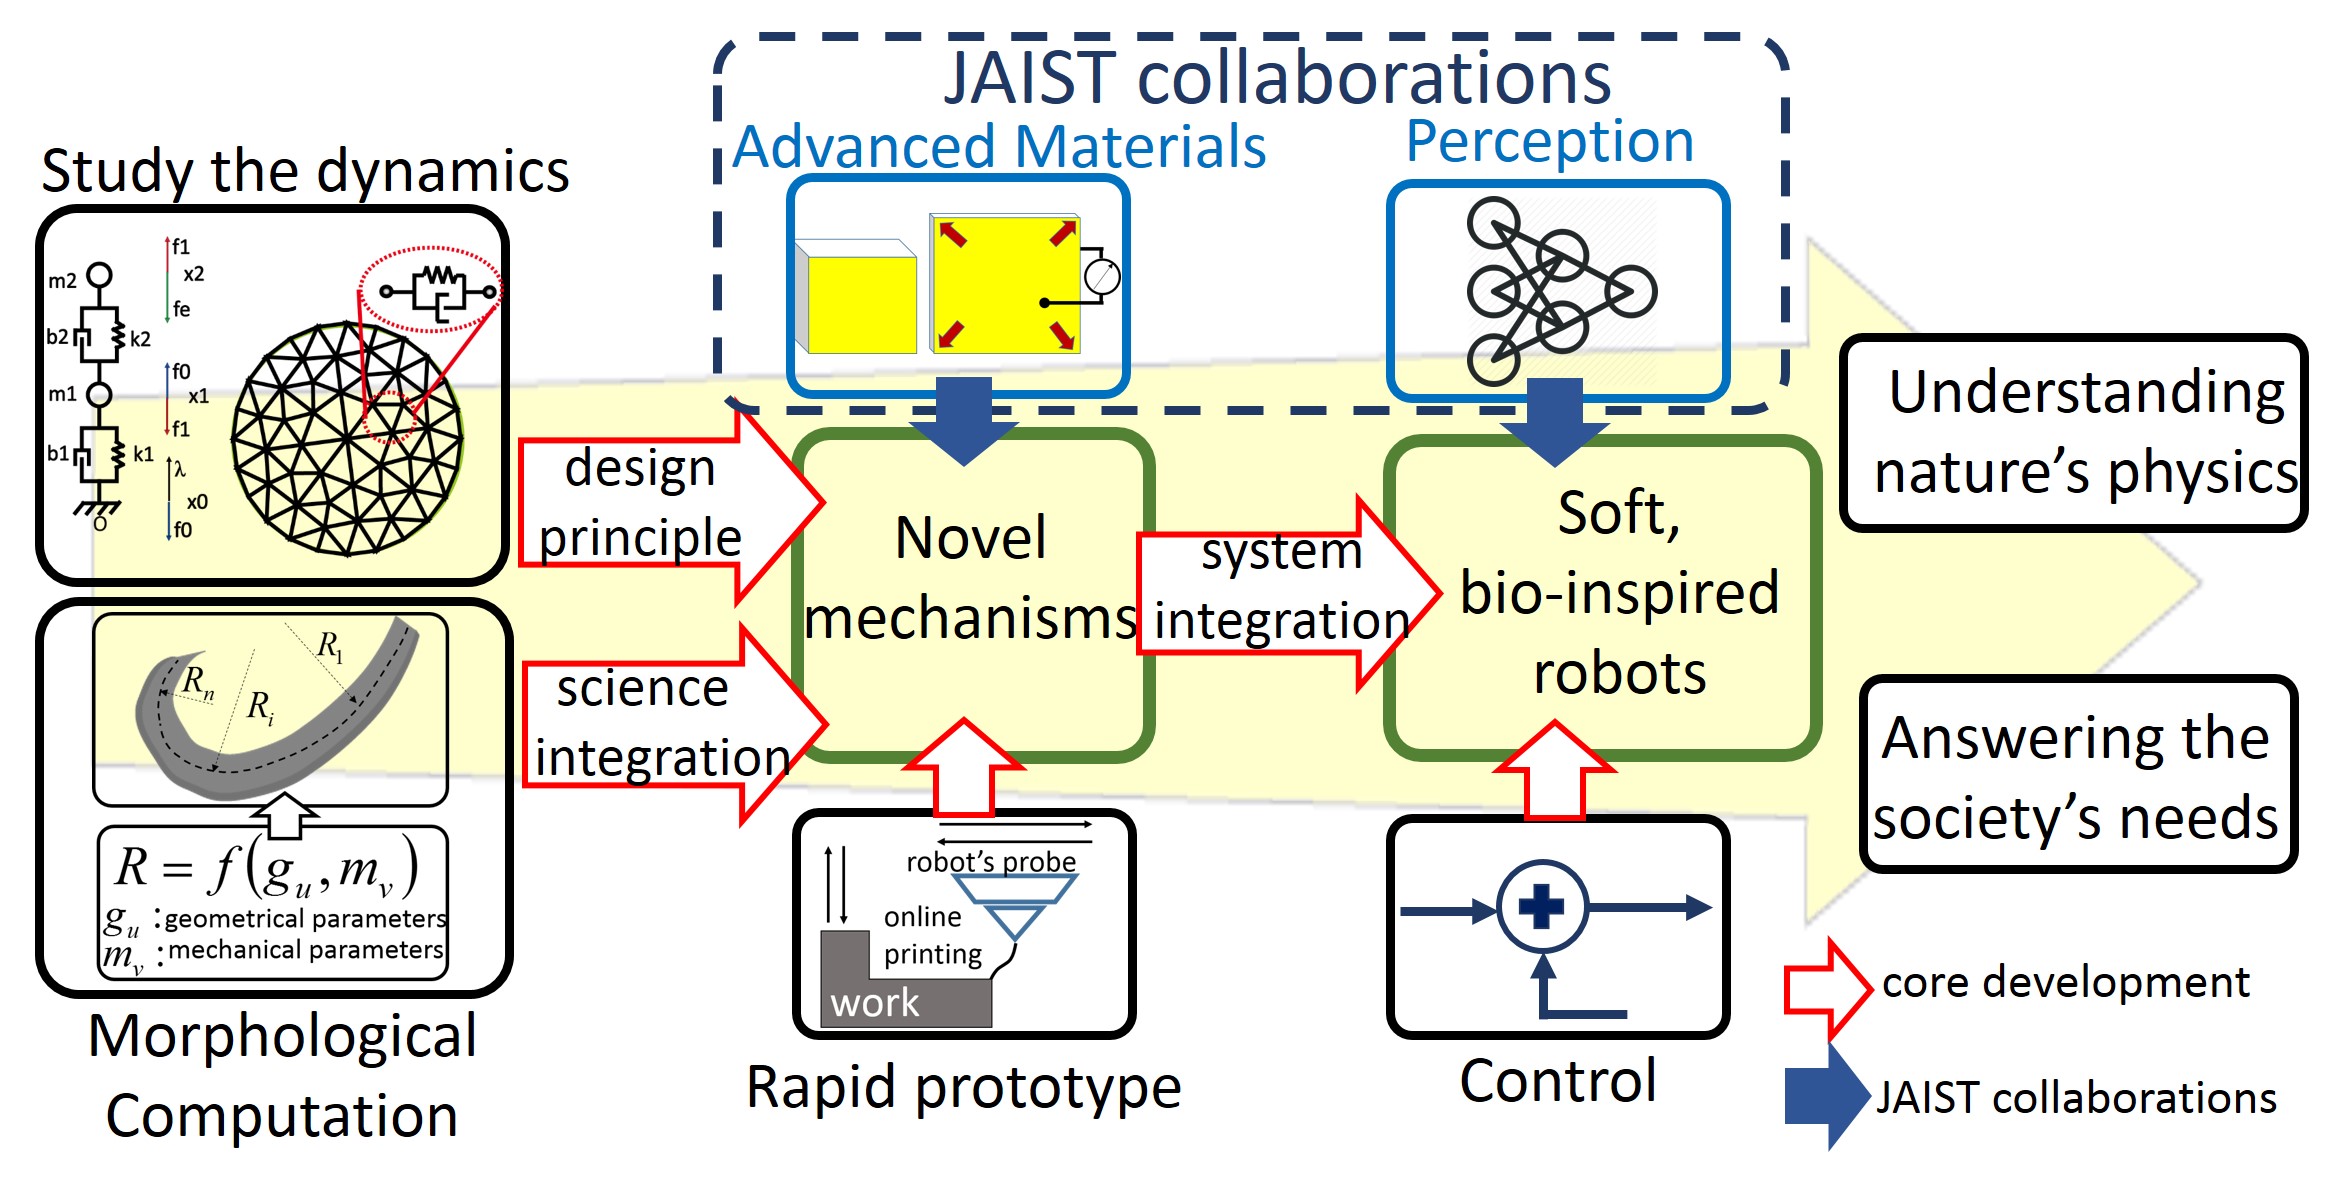
Our Laboratory aims to answer emerging needs of the society by proposals of novel robotic systems, ranging from fabrication of sensors, actuators, and intelligence. We
particulaly focus on dynamic investigation of nature phenomena to find out the underlying, dominating mechanisms that could then give hints to fabrication of novel structures. Ideas are shaped under the light of
novel technologies with integration of scientific methods, then integrated in robotic systems with specific applications. Results obtained in this process could be inversely utilized to understand the natures.
MESSAGE TO POTENTIAL STUDENTS
Robotics is multi-disciplanary research. Our lab welcomes students from diverse backgrounds, such as material science, mechanical engineering, sensor fabrication, control engineering, and information science. Skills
can be achieved during the study, thus, the following minds are encouraged in our Lab: creation, communication, and commitment. Feel free to contact staffs in Lab for further information.
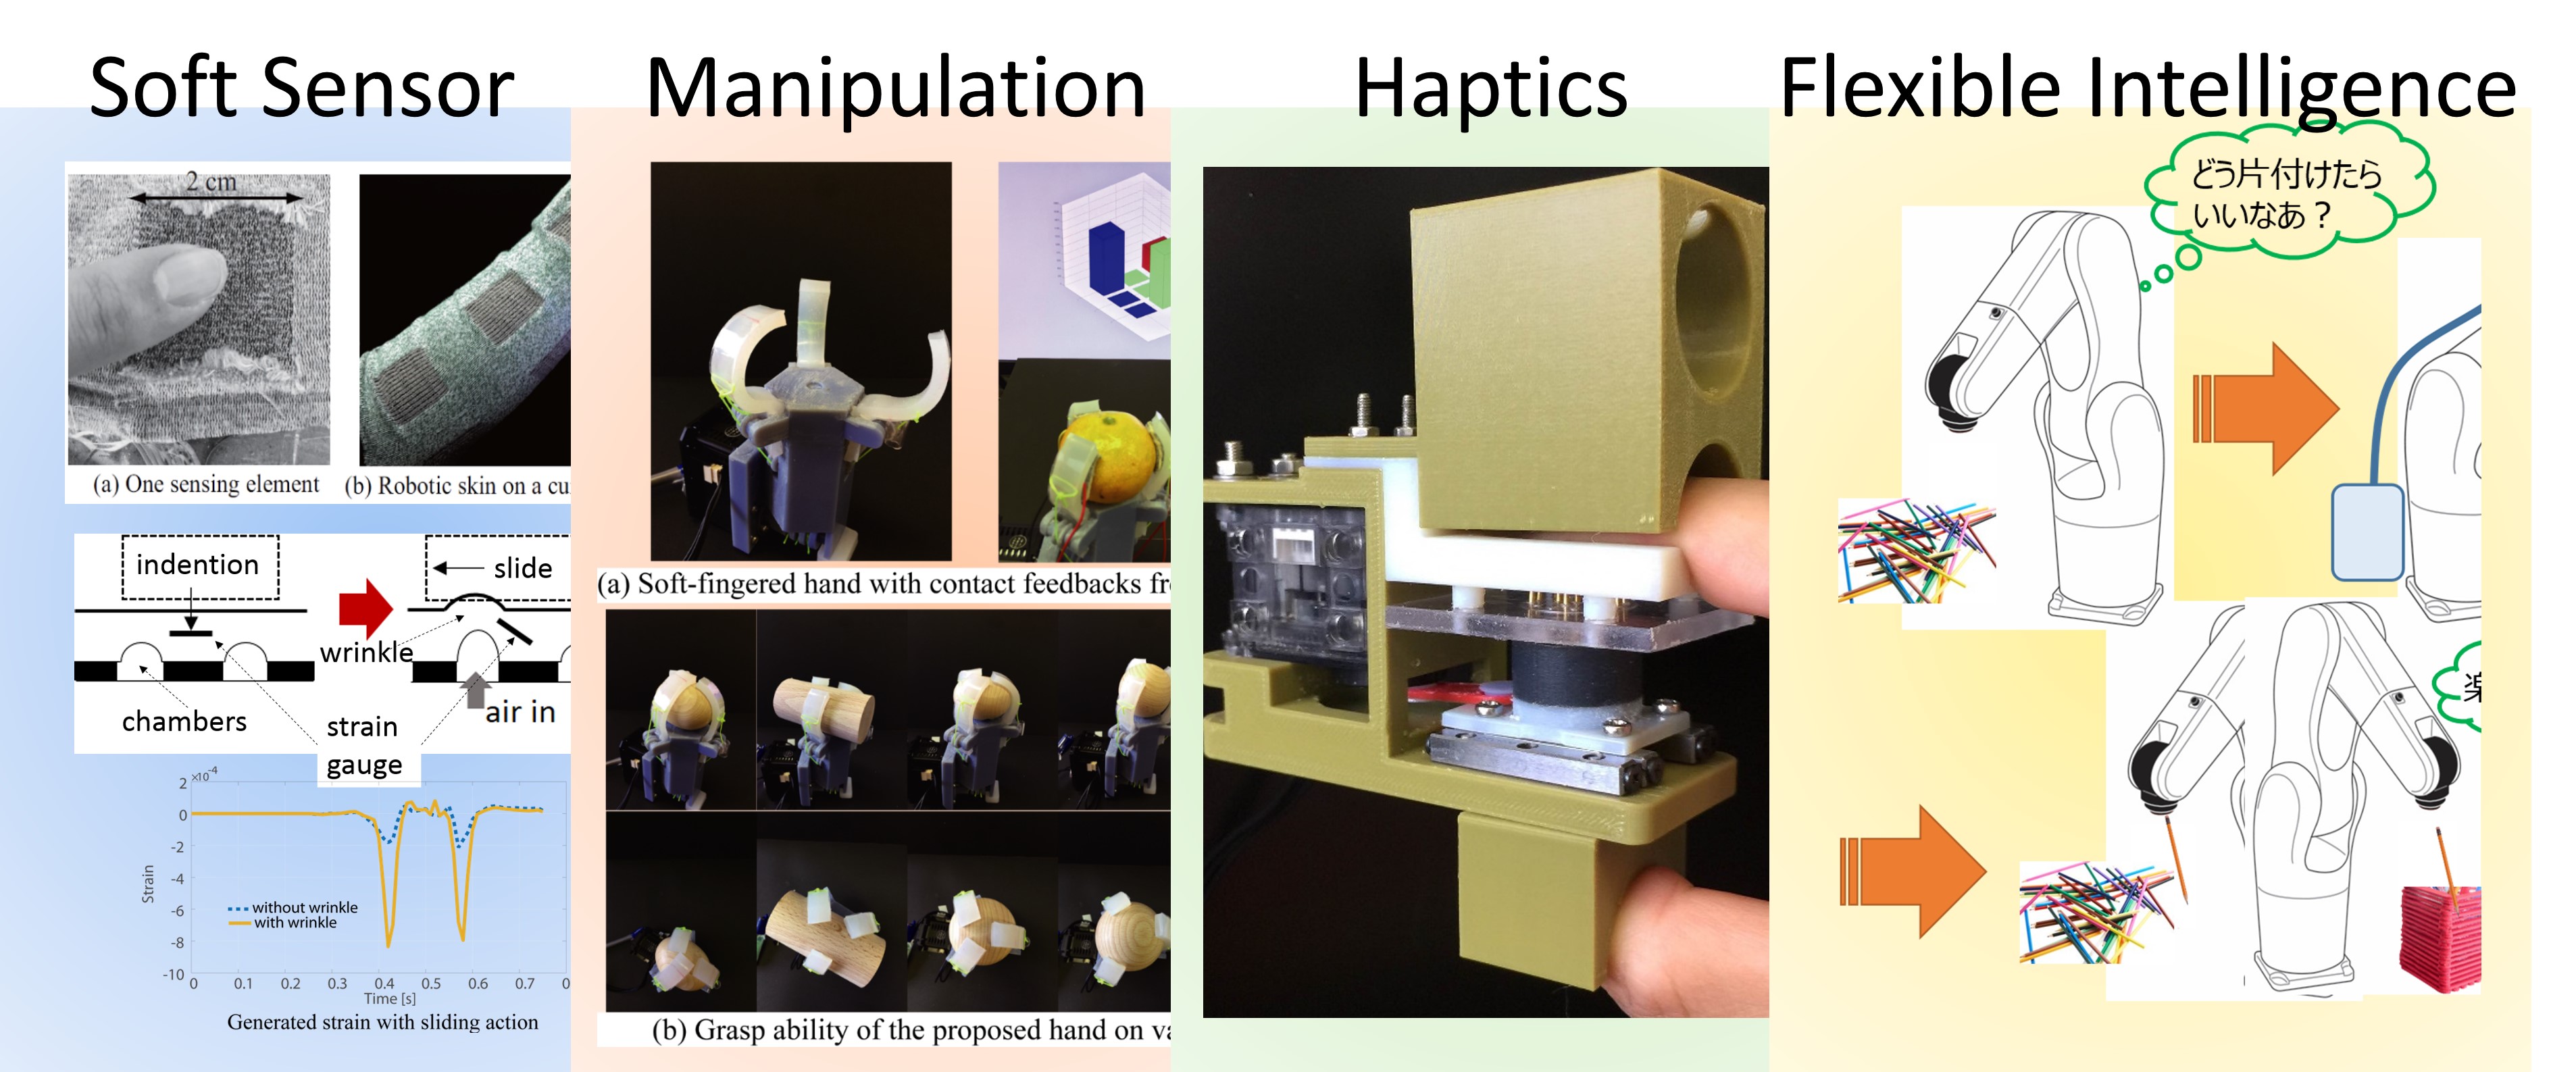
2017/07/01 Paper titled Wrin'Tac: Tactile Sensing System with Wrinkle's Morphological Change has been published by IEEE Transactions on Industrial Informatics (now free for access)
2017/06/14 Paper titled Grasping by Wrapping: Mechanical Design and Evaluation has been accepted by 2017 IEEE International Conference on Intelligent Robots and Systems (IROS 2017), Vancouver, Canada, Sept., 2017
2017/05/01 Workshop proposal on Morphological Design in Haptic Sensation, Interaction and Display has been accepted by 20017 IEEE International Conference on Intelligent Robots and Systems (IROS 2017), Vancouver, Canada, Sept., 20017
2017/05/01 Proposal on soft sensor has been accepted by OMRON Tateishi Science and Technology Foundation2017/04/01 Paper titled: " Morphological Computation in Tactile Sensing: Role of Wrinkle " has been accepted for presentation at 2016 IEEE International Conference on Robotics and Automation (ICRA), Singapore, May 27 - June 2, 2017
2017/04/01 Paper titled: " Design and Analysis of a Soft-Fingered Hand with Contact Feedback " has been accepted for presentation at 2016 IEEE International Conference on Robotics and Automation (ICRA), Singapore, May 27 - June 2, 2017